Junlei Hu
Surgical Robotics Researcher @ Stormlab University of Leeds.

University of Leeds
Leeds, UK
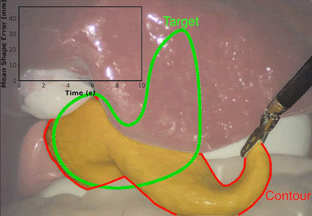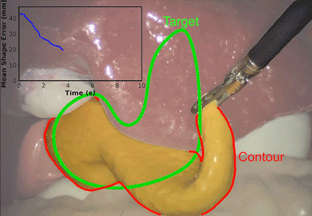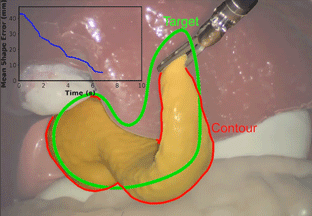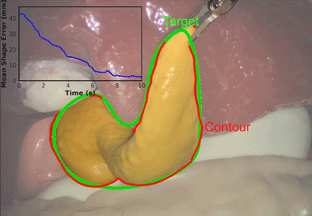
I am a Research Fellow in Medical Robotics at the Stormlab, University of Leeds, where my research focuses on autonomous robotic laparoscopy. I recently earned my PhD from the University of Leeds, where I developed autonomous systems for surgical robotics under the advisement of Prof. Pietro Valdastri. My doctoral research specialized in the challenge of deformable tissue manipulation. I received my M.S. and B.E. degrees from the School of Mechanical Engineering, Shanghai Jiao Tong University.
My current research work is centered on the da Vinci Research Kit (dVRK) for laparoscopic surgery, under the theme “From Conformation to Exploration: Advancing Autonomous Robotic Manipulation of Soft Organs in Laparoscopy”. The project aims to achieve more complete autonomous surgical capabilities, enabling robots to actively manipulate and explore soft organs to improve surgical outcomes.
My research focuses on advancing minimally invasive surgery through innovations in robotics and AI, specializing in three core technical domains:
- Perception: Developing real-time sensing systems for dynamic surgical environments, including deformable soft tissue manipulation and laparoscopic image processing.
- Analysis: Creating interpretable AI models for surgical decision-making through multimodal medical data characterization and uncertainty-aware learning.
- Action: Designing adaptive, safety-critical control systems for autonomous robotic surgery, including motion planning and compliance control.
news
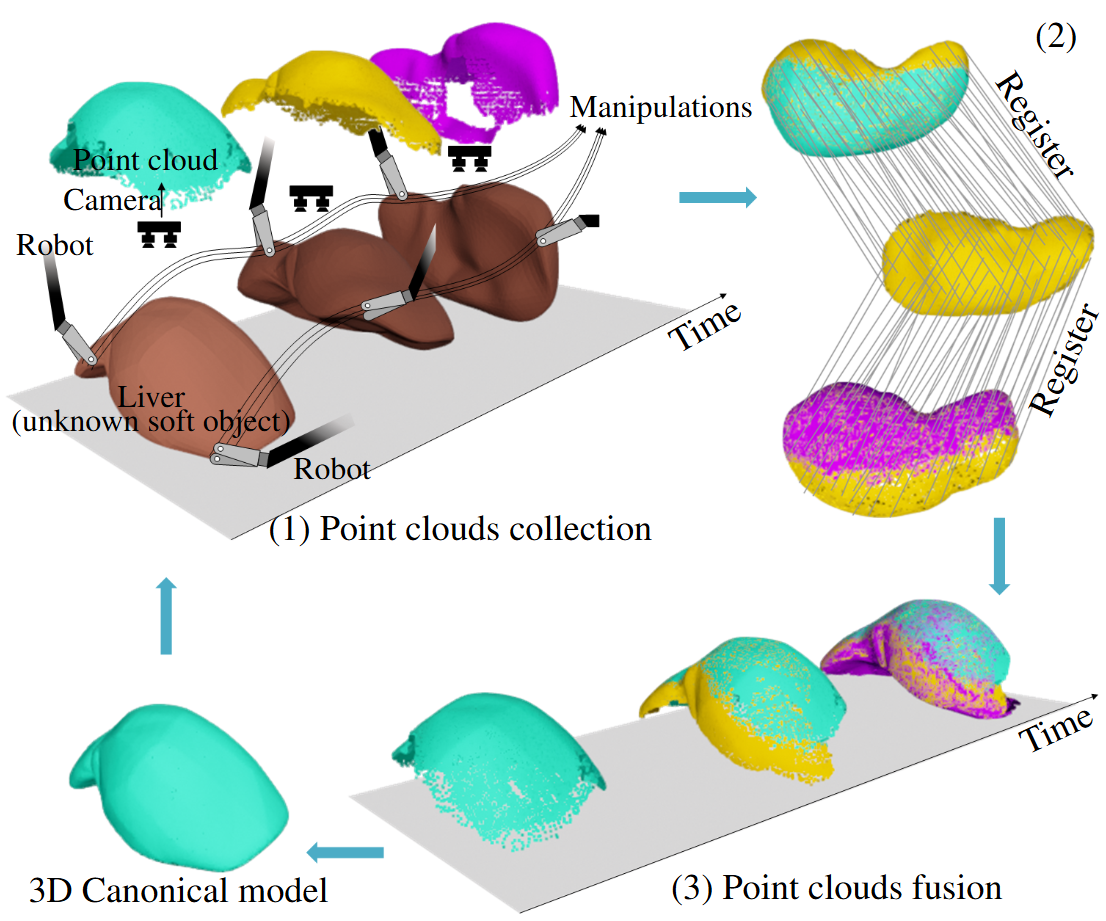
| Oct 2026 | 🎉 Our paper, “Autonomous robotic exploration of unknown soft objects”, is featured on the cover of The International Journal of Robotics Research, Volume 45, Issue 12 (October 2026). |
|---|---|
| Sep 29, 2026 | 📄 New preprint: CADeT: Causal-Aware Deformation Transmission for Indirect Robotic Manipulation of Soft Tissue. Explore the project page and experiment videos or read the paper on arXiv. |
| Aug 10, 2026 | 📊 Our DRENDS dataset for depth estimation in dynamic robotic endoscopy is published in Scientific Data. Read the paper and access the dataset on Zenodo. |
| Aug 04, 2026 | 📄 Our paper, Hybrid Geometric and Latent Shape Servoing for Autonomous Gallbladder Exposure, is featured at BioRob 2026 (August 1–4, Edmonton, Canada). Read the paper on IEEE Xplore. |
| Jun 23, 2026 | 🏆 Our University of Leeds team received the Champion Award for Task 1: Safe Needle Picking and the Best Demo Award for Task 3: Vessel Clipping at AutoSurg 2026, part of the MRC–Hamlyn Workshop in London. |